ISAP-D · LOT 1 RESERVING DESIGNED FOR U.S. PRODUCTION
Robot joint actuators

The Movement America needs.

Imported joints are now a compliance problem. ISAP-D45 and D30 are backdrivable planetary joints built to the Unitree G1 7519's torque and speed, on an open EtherCAT bus, with continuous torque and one price published for every buyer.

Reserve Lot 1 · $2,500 a joint → Talk to an engineer

NVIDIA Inception member · OIST-Lifetime Startup Elevate 2026 · SAM registered, CAGE 267S5

FCC Covered List · foreign-produced robots · since 07.28.2026

Scroll
// 01 — Thesis

Robots are being built here. Their joints are not.

Many of the legged robots in American labs and factories run on imported joints. New FCC rules and the DFARS magnet restriction from January 2027 make that a sourcing problem. Sentinel Automata builds the replacement, one joint at a time, starting with the hip and knee. Designed to NDAA provenance requirements; sourcing verified at first production build.

// 02 — What we make

Two joints, one platform.
Lot 1 reserving now.

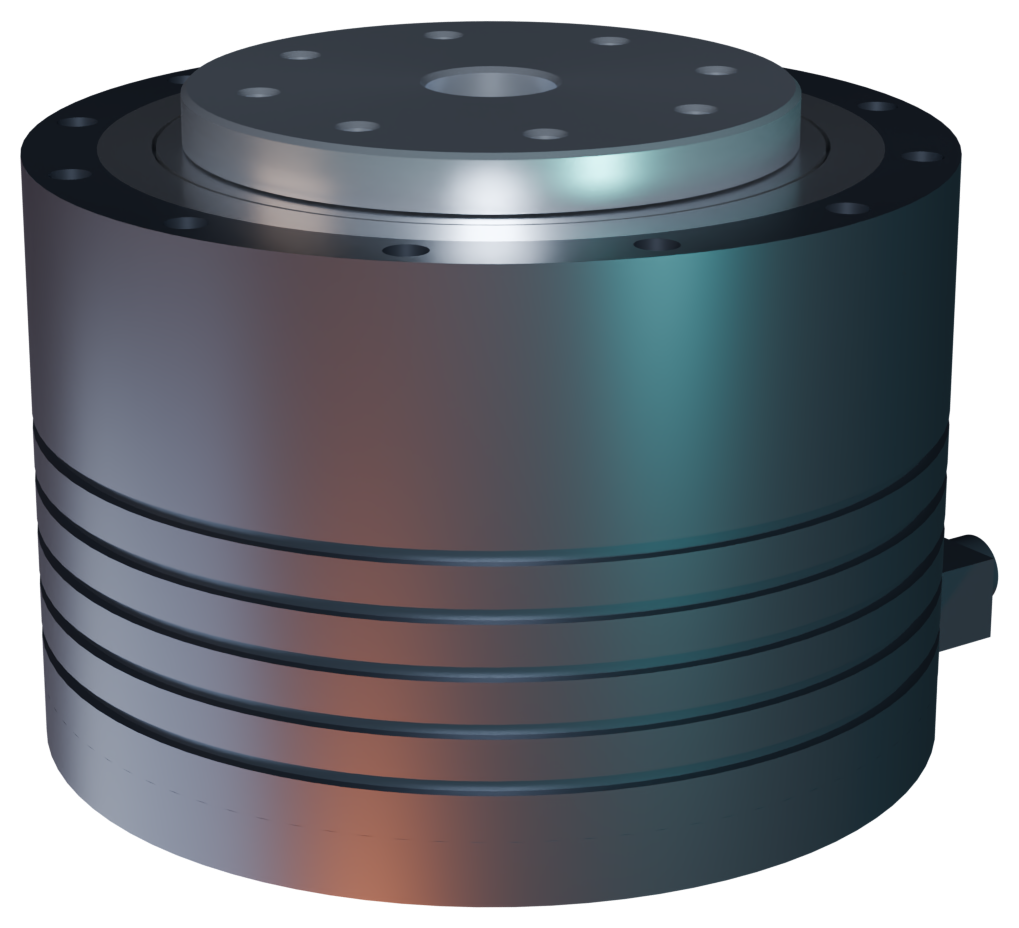
ISAP-D45 and D30 share one motor, housing, board and output bearing; the gear kit sets the SKU. Specs are design targets until the dyno measures them, and we publish the measured datasheet when the first articles pass. Dev kits are on pre-order now, shipping Q1 2027.

ISAP-D45 concept render
Lot 1 reserving now · dev kits on pre-order, shipping Q1 2027

ISAP-D45 / ISAP-D30

Backdrivable two-stage planetary joints on one platform, sized for the hips and knees of legged robots. Open EtherCAT with a published interface, motor and output absolute encoders, no locked firmware. Designed for US production.

ISAP-D45
45 N·m continuous · 139 N·m peak · 191 rpm max · 22.5:1
ISAP-D30
30 N·m continuous · 88 N·m peak · 306 rpm max · 14.3:1
Platform
~75 mm motor, hollow bore · mass ≤ 1.2 kg
Bus
48 V · EtherCAT, CiA 402 · motor + output absolute encoders
Gearing
2-stage planetary · backlash ≤ 15 arcmin · unpowered backdrive ≤ 1.5 N·m
Efficiency
D45 ≥ 75% at 45 N·m, 120 rpm
Production Lot 1: $2,500 per joint, D45 and D30 mixed. One batch of 1,000 joints across buyers; the lot confirms when reservations reach 1,000. Reserve with no payment now; a 20% refundable deposit is due when the lot opens.
$9,500 per joint, dev kit: ships with its own dyno test report and a priority place in Lot 1
Evaluation pair: two dev kits, one D45 and one D30, $14,500, pre-order now, shipping Q1 2027. · volume from $1,300 at 5,000+ a year
One published price for every buyer · US shipping · D20, D14 and D5 gear kits planned on the same platform

Defense autonomy

Manipulator arms on uncrewed ground vehicles, legged and ground robots, and gimbals, where the program needs US provenance. Designed to NDAA provenance requirements; sourcing verified at first production build.

Commercial robot builders

Teams building legged, inspection, agricultural and humanoid robots who need a joint they can source, integrate and talk to over an open bus.

Not what we make

Drone propulsion motors. ISAP is a geared joint for legs, arms and gimbals.

// 03 — Why ISAP-D

What you can check
before you buy.

Leg-class torque

139 N·m peak, 45 N·m continuous and up to 191 rpm: the hip and knee a full-size legged robot stands on, not a wrist or a gripper.

One published price

$2,500 a joint in Production Lot 1, falling to $1,300 at volume. One ladder for every buyer, published on the order page, no quote call required.

Open bus, no locked firmware

EtherCAT with a published interface and absolute encoders on the motor and the output. Your controller talks to it on day one.

Built for the sourcing rules

Designed for U.S. production against the FCC rule for new robots and the DFARS magnet restriction. We say "designed to" until the first production build proves it.

// 04 — Process

The process is the product.
Ours already runs.

The spec is the source; everything else is generated. Every interface drawing Sentinel publishes is rendered live from the ratified interface-control document — the same spec that generates the production geometry and its manufacturing parameters. The drawing you see is generated, not illustrated.

00— SPECIFY

The ICD is code

Each actuator has one ratified interface-control document — bore, pilot, bolt circle, output pattern — written as a machine-readable spec. One source of truth per model.

Ratified · per model
01— GENERATE

Everything derives

Drawings, CAD, and manufacturing parameters derive from the spec. Change the ICD and everything downstream regenerates — including the drawings on this site.

Forge pipeline · live
02— VERIFY

Geometry round-trips

Generated geometry is checked back against the ICD before it ships anywhere. What a partner bolts to is what the spec says — to the tenth of a millimeter.

Checked · every build
// 05 — Posture

Built in America.
Designed to NDAA provenance
requirements from day one.